
Large Spatial Reasoning Models

Rowe 1.0
Upload STEP, IGES, DXF, PDF, SVG, or draw.io → structured cad_scene → Rowe response. Keeps B-rep, dimensions, and constraints for engineering agents instead of flattening drawings to text.
One key. Two calls. Typed geometry back.
Extract a CAD file, drawing, or draw.io diagram into structured JSON, then ask Rowe about it. Every response carries usage and a request id; failed calls are never billed.
OpenAPI 3.1
Import the whole API into your tooling.
MCP server
Tools for Claude Code, Cursor, and any agent.
SDKs
npm install fourechelon · pip install fourechelon
Status
Live health, outside-in, no credentials.
import { FourEchelon } from "fourechelon";
const key = process.env.FOUR_ECHELON_API_KEY!;const fe = new FourEchelon({ apiKey: key });
// A file becomes geometry: path, bytes,// Blob, or { url } for files over ~4 MB.const scene = await fe.cad.extract({  file: "cabinet.drawio",  targetContract: "both",});scene.structure?.kind; // "diagram2d"scene.structure?.pages?.[0].relations;// [{ type: "contains", subject: "cab",//    object: "plc" }, ...]
// Ask Rowe about the same geometry.const answer = await fe.responses.create({  input: {    task_type: "understand",    cad_scene: scene,  },});
Reason OnDataText

Multimodal Spatial Inputs
Combine point clouds, camera frames, maps, sensor readings, location traces, and metadata into one model context for spatial reasoning.
Structured Answers
Ask for fit checks, object relationships, scene state, route constraints, or risk signals and receive outputs your application can use directly.
Context Across Systems
Reason over live feeds, historical data, and external systems together so decisions reflect the full operating picture.
Developer-Ready API
Send spatial data through a simple responses API and get typed results, usage metadata, and request IDs for production workflows.
Understand the Physical World
Spatial Relationships
Identify objects, boundaries, distance, orientation, containment, occlusion, and proximity across complex real-world scenes.
Physical Constraints
Understand fit, stability, collision, reachability, line of sight, and movement constraints before acting in the world.
World State Reconstruction
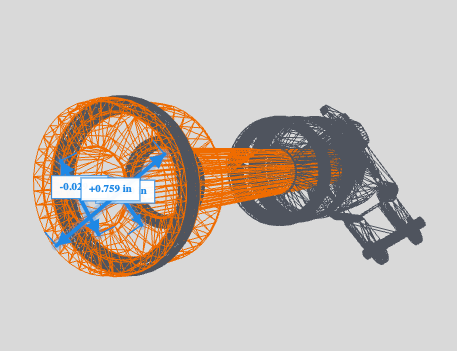
Convert partial observations into useful 3D state: reconstructed structure, tracked objects, and scene-level understanding.
Built by Engineers From


Predict The Future

Future Position Estimates
Project where objects, devices, vehicles, or people are likely to move next based on live state, motion history, and spatial constraints.
Simulation Scenarios
Run what-if scenarios across physical environments: routing, placement, congestion, collision risk, coverage, and operational outcomes.
Actionable Forecasts
Return structured predictions and recommended actions your systems can use for alerts, planning, routing, and automation.
Start Here
Geometry infrastructure for engineering AI. Upload a file, get structured JSON, reason over it — in that order.